Overview
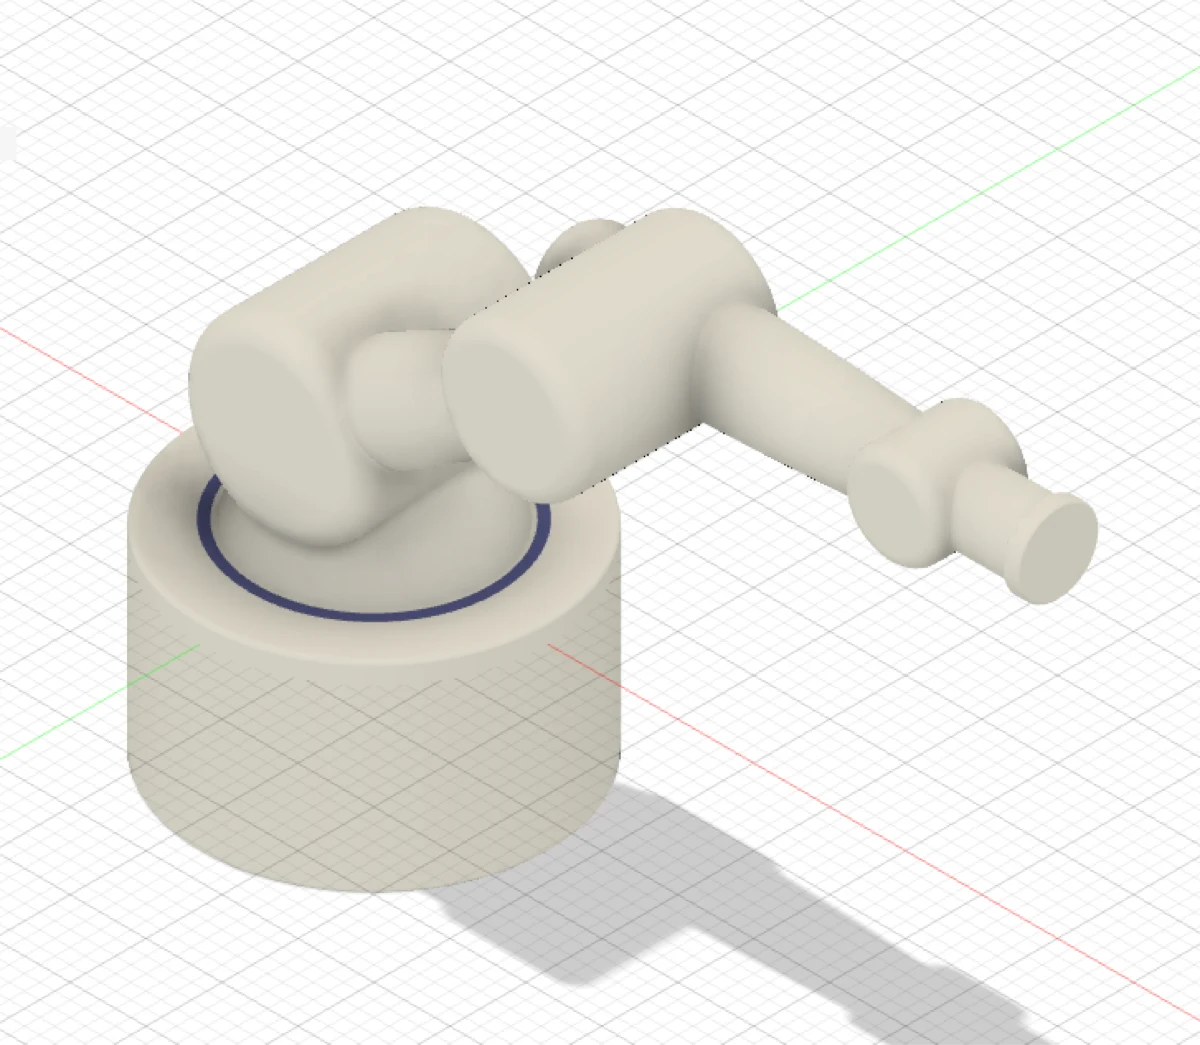
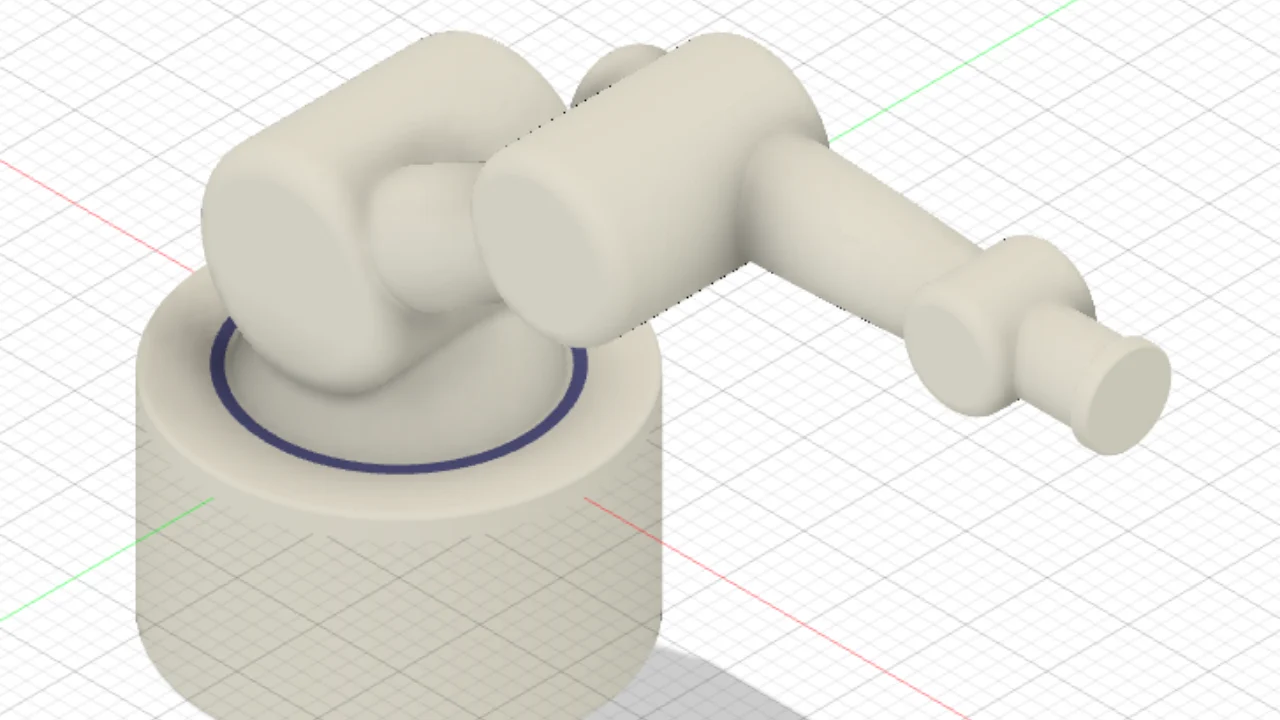
A desktop robotic arm being designed in Fusion 360. The current model fixes the kinematic layout — a rotating base, shoulder and elbow joints, and a wrist stub where a gripper or tool will mount.
Design So Far
- Cylindrical base housing the shoulder rotation, with a bearing ring at the turntable
- Shoulder and elbow joints setting the arm's reach envelope
- Tapered forearm leading to a wrist stub for the end effector
Still To Do
- Actuator selection, with motor and gearbox mounting
- Internal cable routing and fastener design
- Splitting into printable parts, tolerancing, and a first test print