Overview
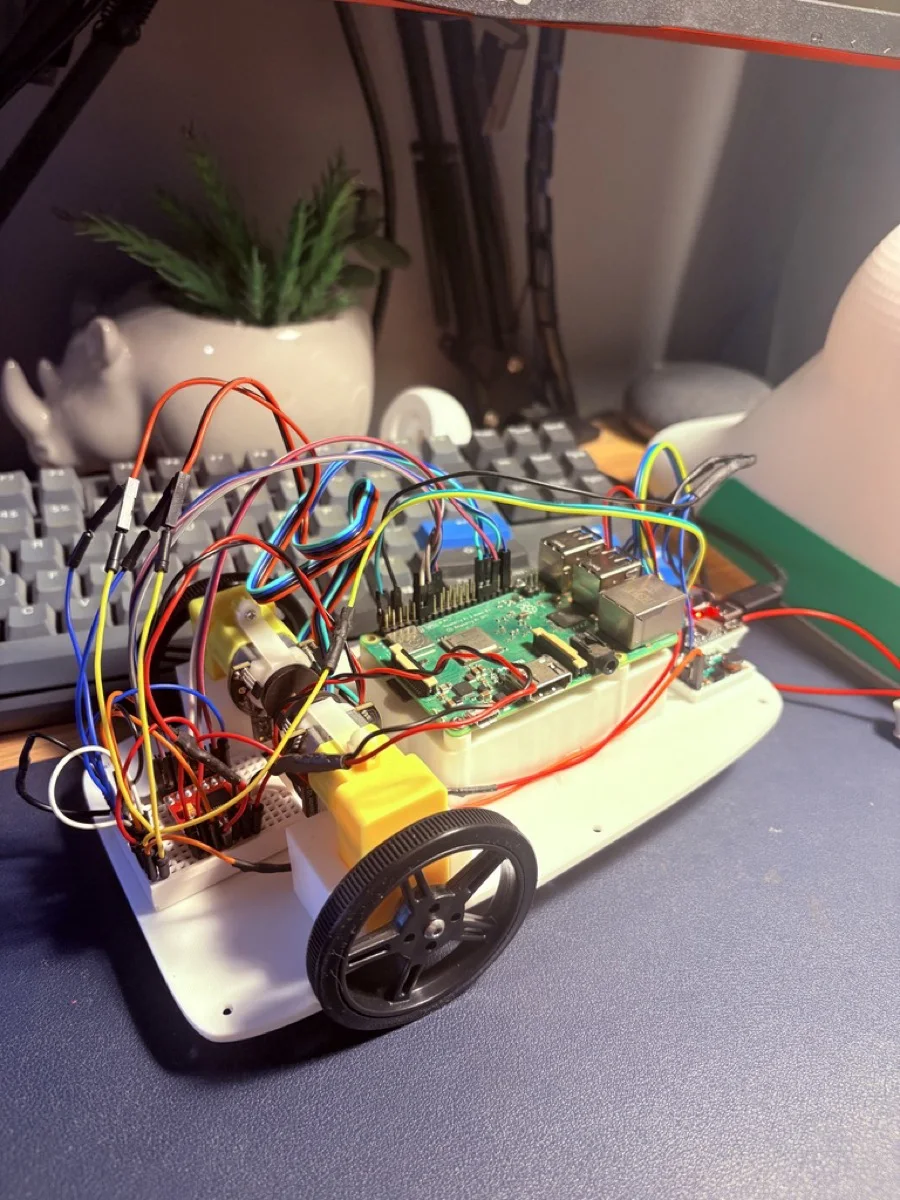
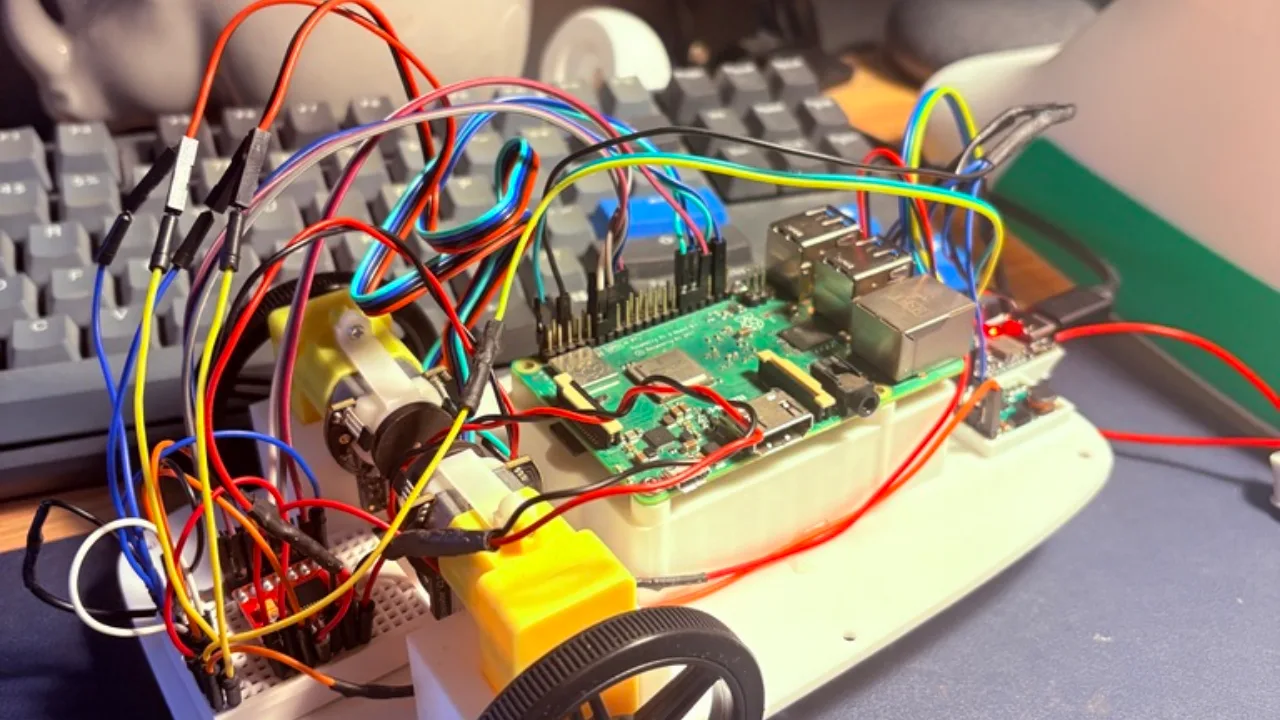
A two-wheeled robot built around a Raspberry Pi on a 3D-printed chassis. The prototype deliberately keeps the driver circuit on a solderless breadboard so the wiring and control logic can change quickly between tests.
Current Build
- Raspberry Pi as the main controller, fed from an onboard power module
- Two gear motors driving the wheels through the printed chassis mounts
- Breadboarded motor driver and GPIO wiring for fast iteration
- 3D-printed chassis carrying the controller, driver circuit, and power
Still To Do
- Move the driver circuit from breadboard to a soldered board
- Tidy the wiring loom and secure the power supply
- Closed-loop drive control and a first autonomous mode